Capacitive Touch Sensing
2024
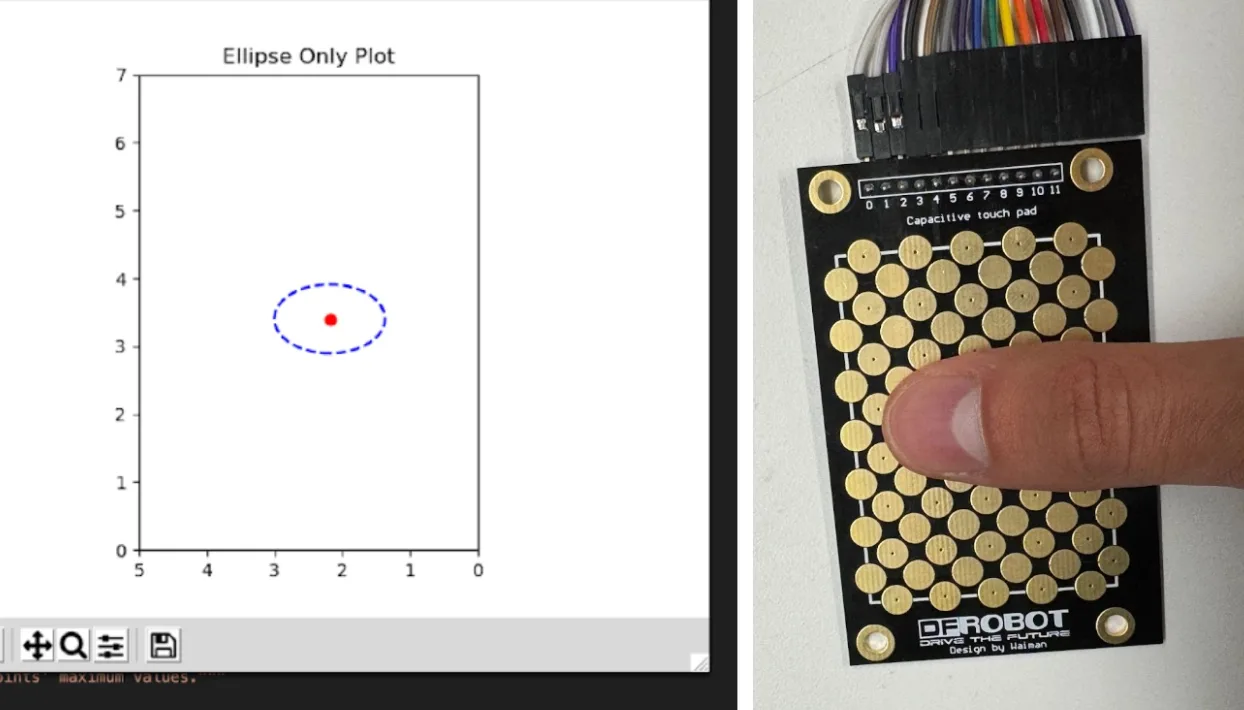
Capacitive Touch Sensing
Using a capacitive touch sensor, we implemented PRBS drive and sense lines to track touch. Our code generated both a heatmap of the touch as well as a centroid estimate.
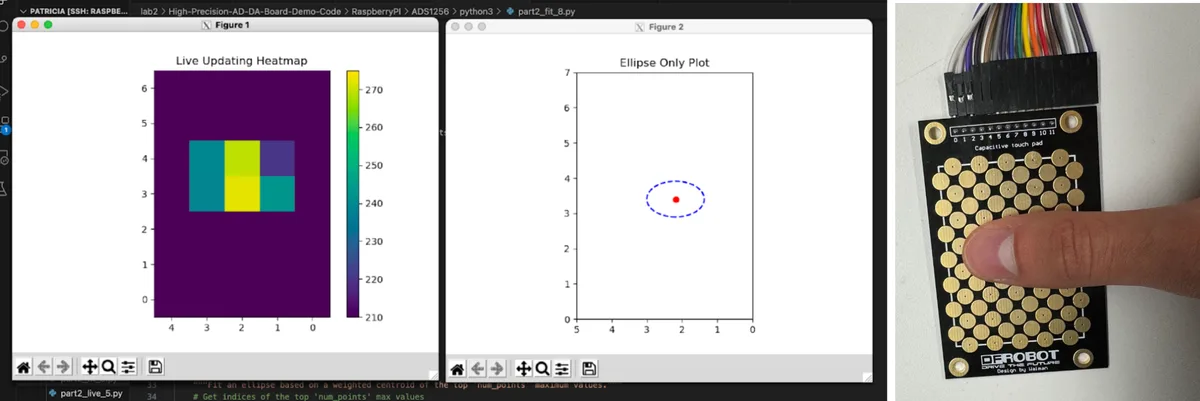
Description
- Implements capacitive touch sensing using PRBS-driven lines and cross-correlationbased detection on sense lines.
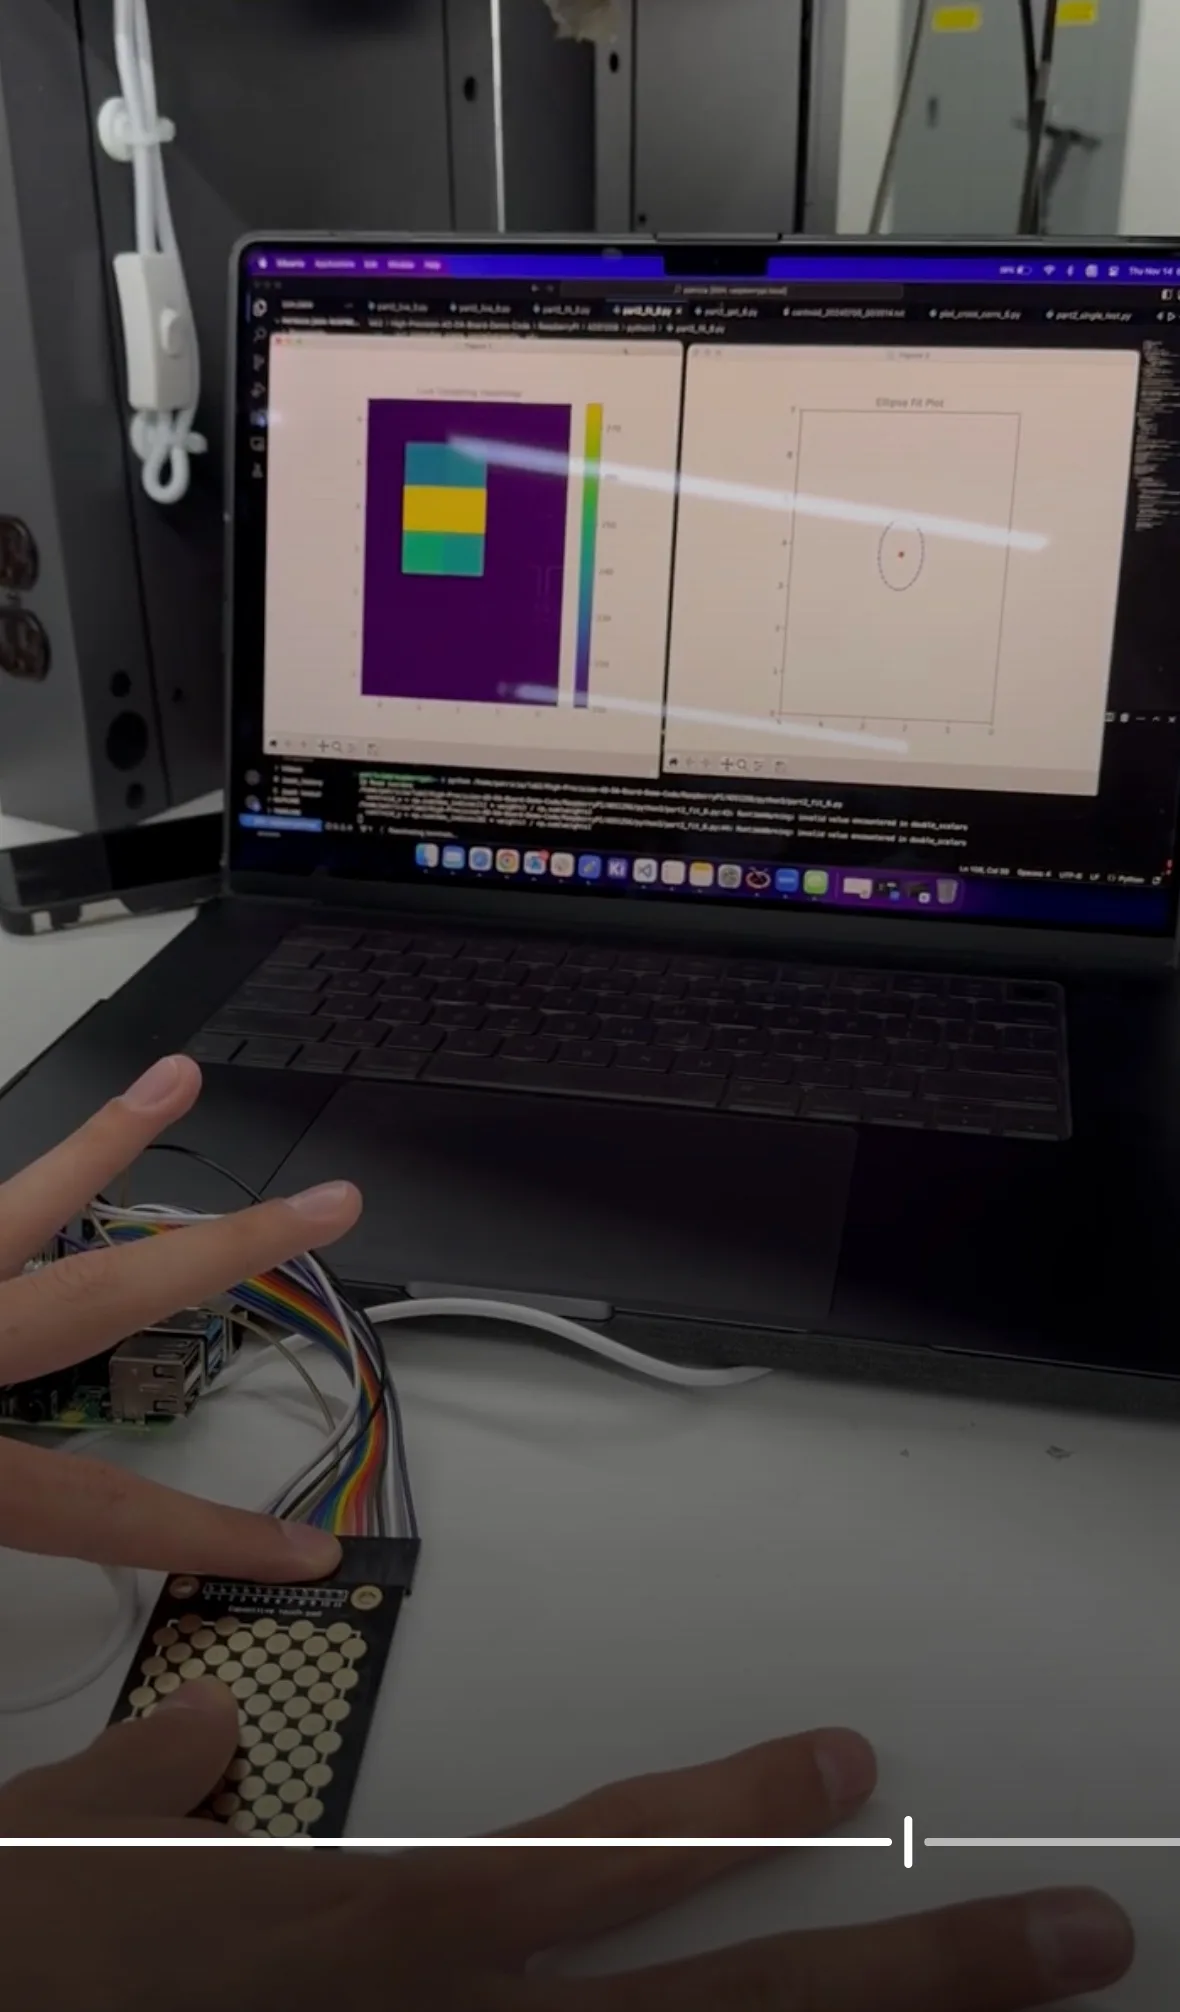
- Generates a real-time touch heatmap and calculates a centroid from sensor input.
- Optimizes sampling and frame rate to balance responsiveness and precision (up to 6 fps).
- Demonstrates trade-offs between short vs. long PRBS sequences for speed and accuracy.
- Uses Kalman filtering to estimate touch location and velocity, enabling gesture tracking.
- Touch data is visualized live, including ellipse fitting and heatmap overlays.
- System built and tested with noise analysis, baseline correction, and bit-length tuning for robust detection.
Learning Outcomes
1. Technical Skills & Knowledge
- Capacitive touch sensing principles and PRBS signal generation
- Cross-correlation algorithms for localization
- ADC configuration and sampling rate analysis
- Real-time data plotting and signal noise handling
- Application of 2D Kalman filters for motion estimation
- Comparative evaluation of signal bit-lengths for design tuning
2. General Project/Practical Skills
- Trade-off analysis: Accuracy vs. speed in sensing systems
- Experimental design and controlled testing for performance evaluation
- Interpreting and processing large sensor datasets
- Clear documentation through visuals, live demos, and code organization
Documentation
Reach full documentation and demos here: https://docs.google.com/document/d/1w31i9TI1qzB_Jlte6xMf54AVjQe2aJYGS4aqW-wkKgk/edit?usp=sharing
All the code and demo videos are in: https://drive.google.com/drive/folders/1IhsBLmNXyd7g-sWnGCal_qK_OI29GPDY?usp=sharing